Praxis-1
Is Now Available
by Praxis Research
Praxis-1, a state-of-the-art world action model, is now available with open weights under the Apache 2.0 license. It builds on the same large-scale video pretraining behind modern world models and is ready for robotics developers and researchers to run, inspect and adapt.
Launch partners have already tested one checkpoint across different bodies: a legged humanoid from Noble Machines, a six-axis industrial arm from Standard Bots and a dual-arm warehouse robot from Ultra. The same model is now available to every robotics team.
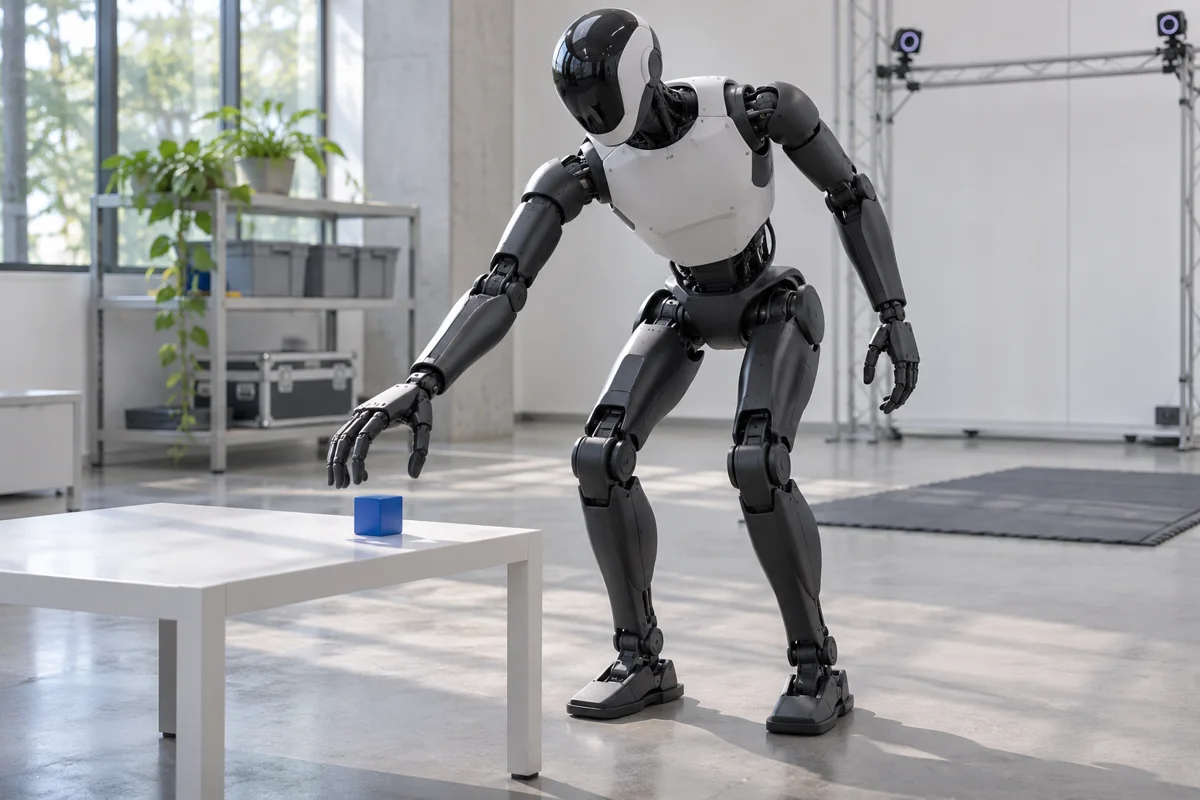
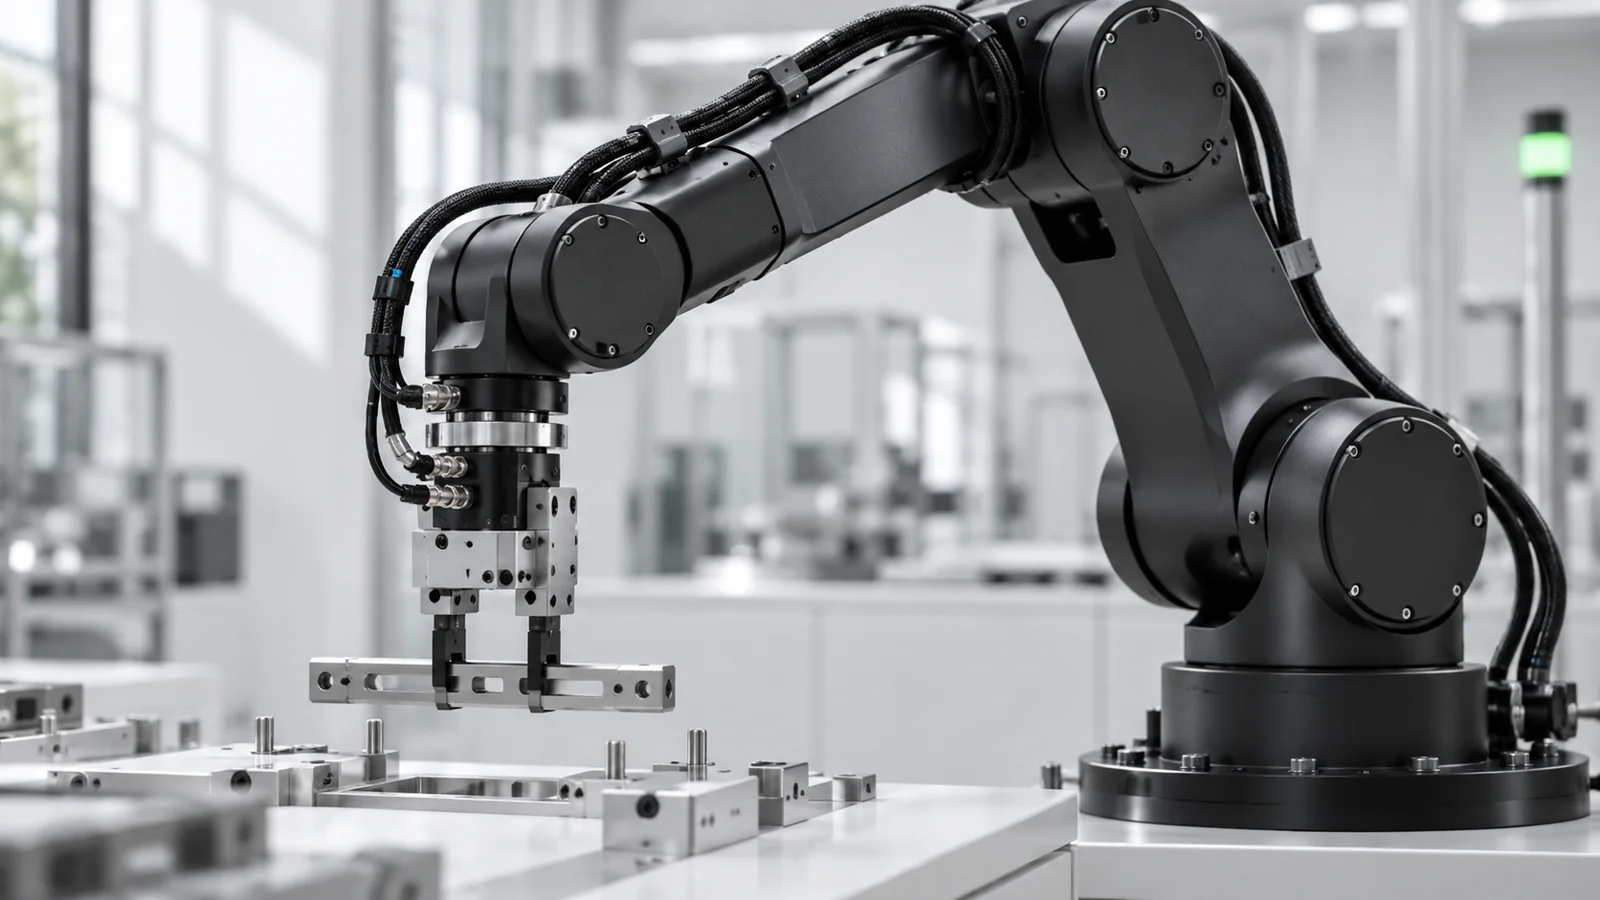
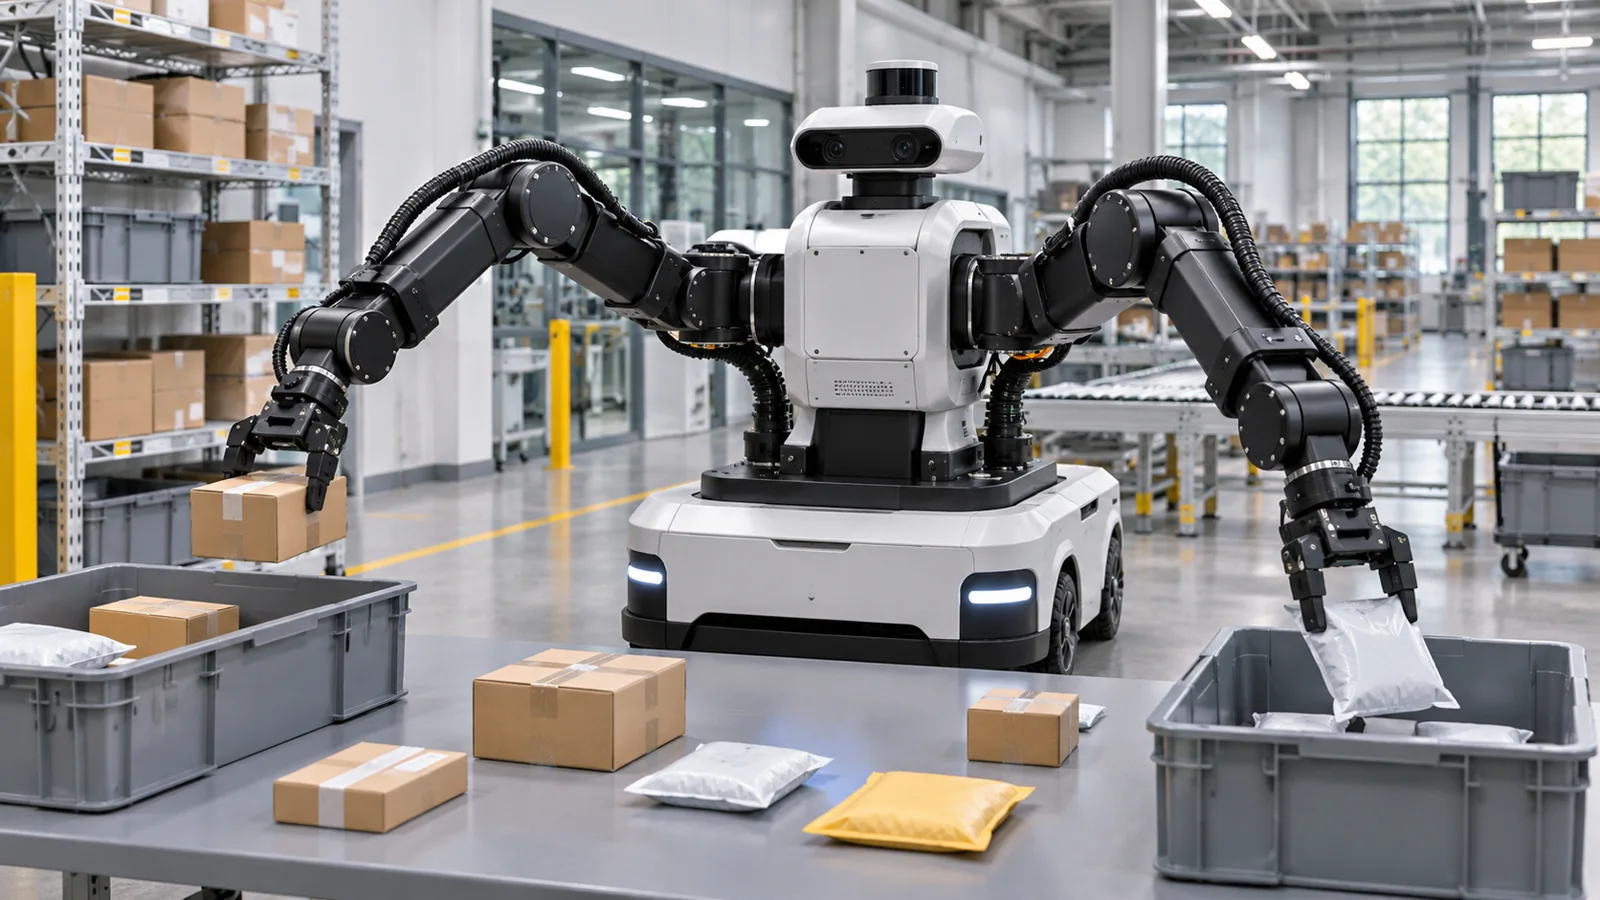
Representative partner deployments.
State-of-the-art performance
Praxis-1 is a 27B-parameter mixture-of-experts diffusion transformer that predicts video and actions together. It leads NVIDIA's RoboLab-120 benchmark for world action models and outperforms open-weight vision-language-action alternatives.
Across 1,200 episodes, Praxis-1 reaches 46.2% success, ahead of FLUX 3 Action at 42.9%, Cosmos3 Nano at 36.8% and π0.5 at 28.0%.
| Model | Success rate |
|---|---|
| Praxis-1 | 46.2% |
| FLUX 3 Action | 42.9% |
| Cosmos3 Nano | 36.8% |
| π0.5 | 28.0% |
Data as of November 2026 · Success rate across 1,200 episodes
Available across the robotics stack
Start from the weights on Hugging Face, inspect the code on GitHub, or use native LeRobot support. The release also includes vLLM-Omni integration, full fine-tuning and LoRA, commercial-use rights and support for NVIDIA hardware from data center GPUs to Jetson Thor.
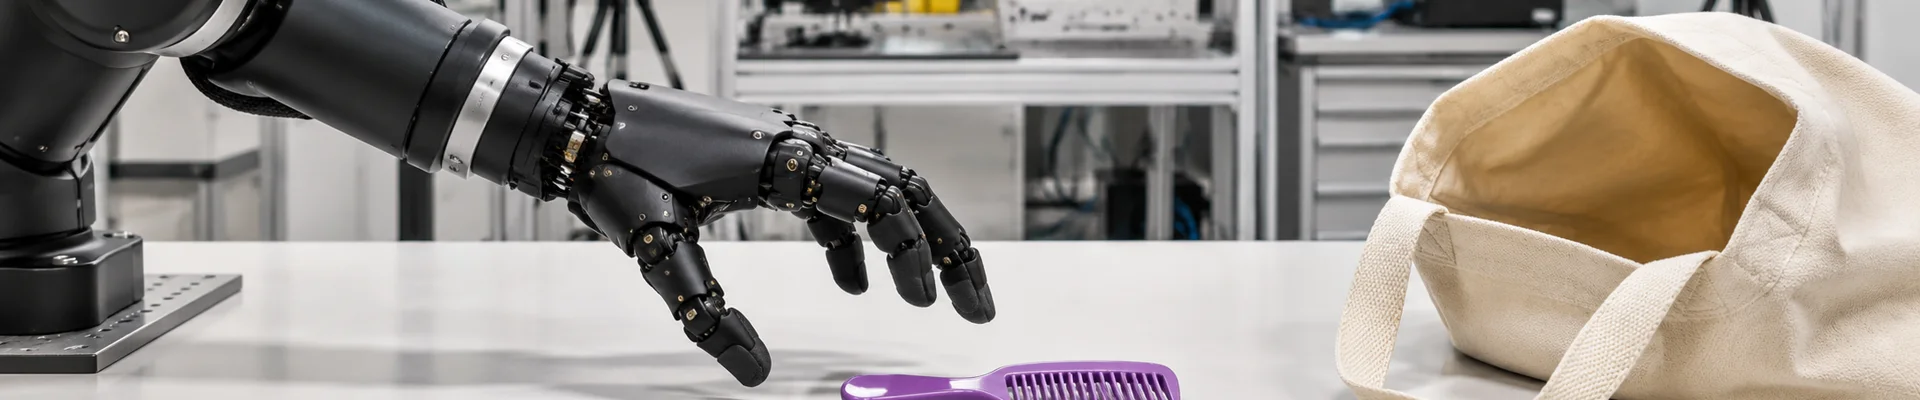
Pick up the purple comb and place it in the bag
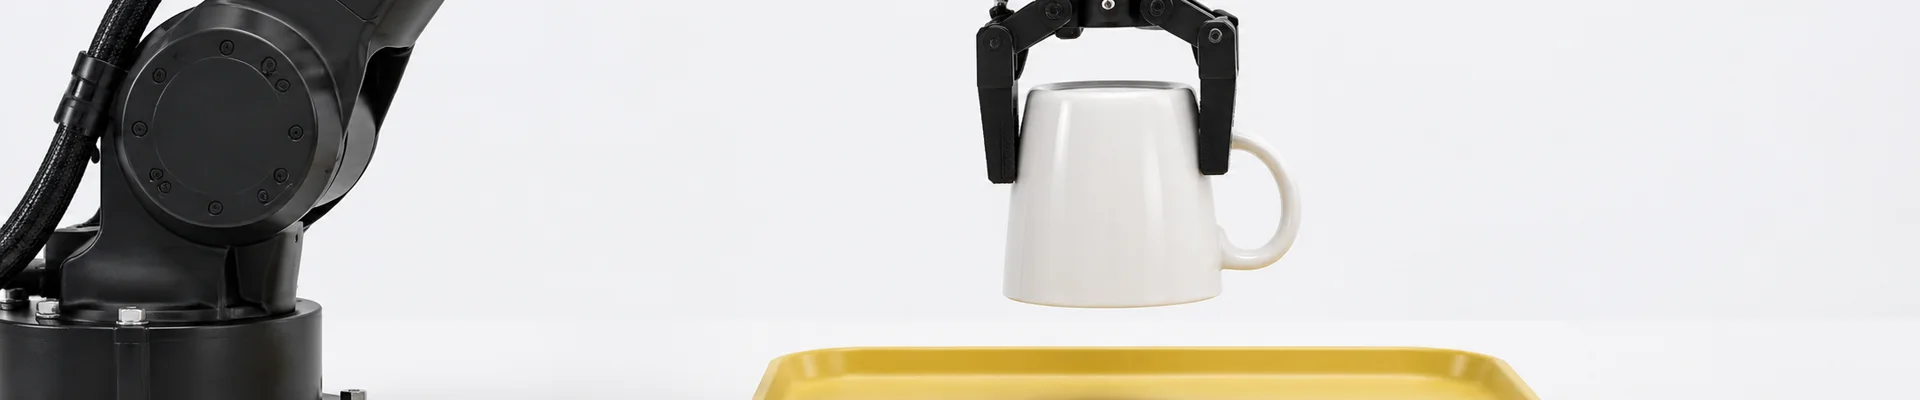
Place the white mug upside down on the yellow tray
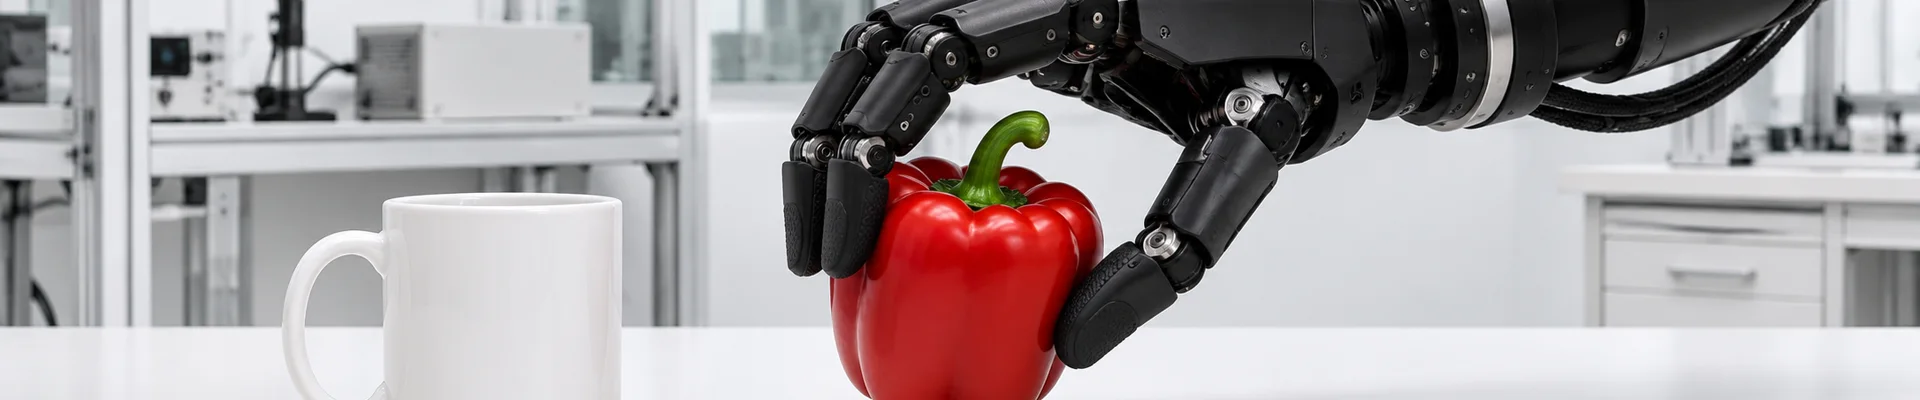
Pick up the red pepper and place it in the mug
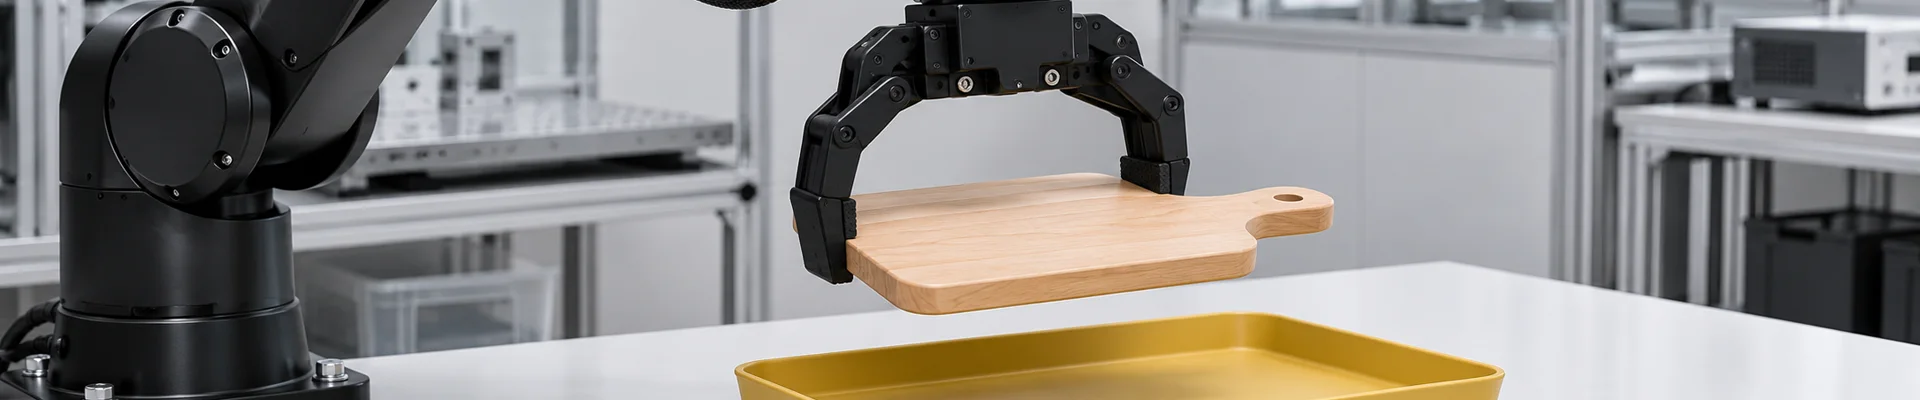
Place the cutting board in the yellow tray
All demonstrations shown at 1× speed.
Adapt it to your hardware
Praxis-1 learns object behavior and task progression from large-scale video. That gives a new robot a useful starting point before it sees any domain-specific teleoperation data. Research shows web video can match teleoperated robot video as pretraining data, shifting the bottleneck toward scale and diversity.
Light fine-tuning adapts one checkpoint across embodiments. With LoRA, teams can target their own cameras and tasks without retraining the full model. On Google's RT-1 robot, Praxis-1 reached 80.0% success in SimplerEnv after fine-tuning, compared with 52.4% for the original RT-1 policy.
H100 · B200
Train, evaluate and serve policies on production NVIDIA infrastructure.
RTX 5090 · RTX PRO 6000
Run local experiments on high-end workstations without a cluster.
Jetson Thor
Keep inference close to sensors, cameras and actuators at the edge.
Why open weight
Physical AI needs interoperable foundations. Open weights let hardware teams inspect behavior, run policies locally and adapt a world action model to their own constraints. Praxis-1 advances the open model ecosystem through the Cosmos Coalition and joint work with NVIDIA to give researchers shared foundations for physical AI.
Move inference from cloud clusters to workstation and edge hardware.
Review weights, inference code and fine-tuning paths under Apache 2.0.
Use full fine-tuning or LoRA for new cameras, tasks and robot bodies.
Try it today
Download Praxis-1 on Hugging Face, inspect the code on GitHub or explore the hosted research demo. Developers can post-train the model for domain-specific work with NVIDIA NeMo Automodel tutorials.